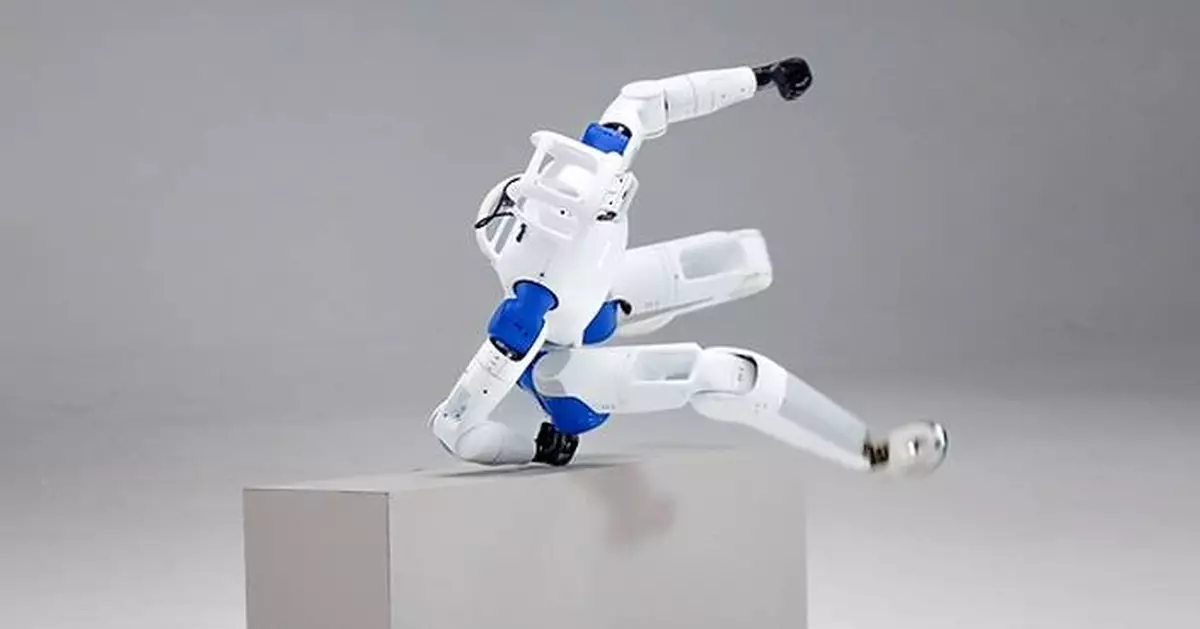
SHANGHAI, Oct. 16, 2026 /PRNewswire/ -- RoboParty today officially launches RP1 (ROBOTO 01), a high-performance, full-stack open-source humanoid robot designed for advanced robotics research and embodied AI development. With open access to both hardware and software, RP1 enables researchers to customize the system, integrate their own algorithms, and test new approaches on real hardware.
As AI increasingly moves into the physical world, humanoid robots are becoming a key platform for the next generation of embodied intelligence. But if their core technologies remain hidden inside black boxes, will innovation be defined only by the few who have access to the underlying systems?
The future of embodied AI should not be built on technological black boxes. Every researcher and developer should have the opportunity to participate.
AI models continue to advance, yet the physical systems that bring their capabilities into the real world still face significant limitations.
For robotics researchers, closed hardware and low-level control systems restrict experimental flexibility and system innovation. For embodied AI developers, limited visibility into a robot's internal behavior makes it difficult to pinpoint problems across model policies, control systems and hardware execution.
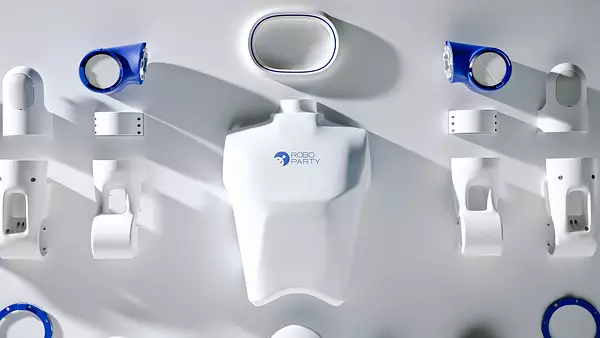
RP1 addresses these limitations by opening access to its robot body design and technical resources for RoboParty's in-house-developed ROMOMO joint actuator modules, alongside technical documentation and research materials. Together, these resources establish an open development ecosystem encompassing mechanical structures, actuators, motion control, simulation environments, software development kits (SDKs) and training tools.
Full-Stack Open Source Across Hardware and Software
Open-source robotics should extend beyond software interfaces. To advance humanoid robotics research, developers need to understand, modify and validate the physical systems that underpin intelligent behavior.
RP1 was built around this principle.
At the hardware level, RP1 integrates RoboParty's in-house-developed ROMOMO joint actuator modules with an optimized mechanical structure and motion-control architecture. Its low-level drivers and control algorithms are also fully open source, with the software stack extending to firmware, development tools, simulation resources and robot learning frameworks. Access to hardware designs and underlying technologies allows researchers to explore the relationships among mechanical design, joint response, control behavior and learning policies.
Researchers can go beyond sending commands to a fixed robot platform. They can analyze and modify the underlying systems that determine how the robot executes movement.
When a robot fails to perform an intended action accurately, the cause may lie in the model, control policy, actuator response or mechanical structure. An open development ecosystem enables researchers to trace problems across these layers and optimize them together, with access to systems they can inspect and modify.
True open source extends beyond code to the robot itself, putting full control of the system in developers' hands.
Designed to Adapt to Research Needs
The standard RP1 stands approximately 1.3 meters tall and features 24 actuated degrees of freedom (DoF), supporting research into gait, balance control and sim-to-real transfer. The Pro version features 30 actuated DoF, including a 2-DoF neck and two 7-DoF arms, supporting research into end-to-end policies, human-robot interaction and data collection for embodied AI. These DoF counts exclude the dexterous hands.
RP1's modular structure and open control interfaces allow research teams to adapt the platform to their experimental needs. Teams can begin with bipedal locomotion research, then configure additional hardware and software for perception, data collection or manipulation experiments.
Interchangeable head modules and wrist end effectors support multiple configurations, including RoboParty's in-house-developed RP Hand dexterous hand. These interfaces allow teams to conduct a range of experiments on the same robot platform.
Open hardware and software also support controlled experiments. Researchers can compare different control methods on identical hardware or hold the control method constant while examining how hardware configuration changes affect experimental results. Recording hardware versions, software configurations and test conditions helps teams trace the causes of differences in results.
Enabling Developers to Focus on Embodied AI Models
RP1 already supports foundational motor capabilities, including continuous walking, recovery from external disturbances, getting back up after a fall and human motion tracking. These capabilities provide an established foundation for embodied AI model development, reducing the need for teams to repeatedly develop low-level motor skills and allowing them to focus on higher-level intelligent policies and complex tasks.
For Whole Body Intelligence development, RP1 provides a robot body capable of dynamic motion, whole-body control (WBC), and supporting tools for virtual reality (VR) teleoperation, data collection and playback, and motion retargeting. It also provides integrated development workflows for WBC-based whole-body motion execution, teleoperation using VR or motion-capture devices, and RP Hand control.
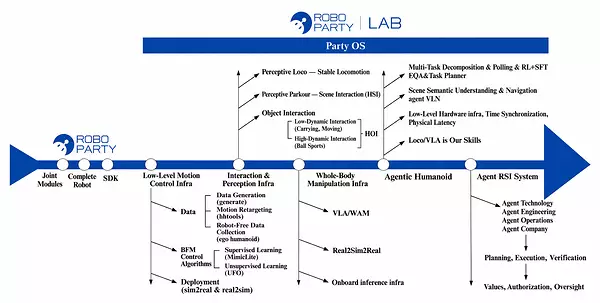
WBC coordinates the arms, torso and legs to support dynamic motion tracking and posture adjustment, providing a stable motion-execution foundation for tasks that combine locomotion and manipulation. Integrated with RoboParty's in-house-developed PartyOS embodied AI system, the UFO unsupervised reinforcement learning framework and MimicLite motion imitation technology, RP1 supports motor skill learning, control policy development and higher-level applications.
RP1 also provides an open toolchain spanning data collection, training in simulation, deployment on physical robots and experimental validation. Researchers can deploy models on the robot, analyze discrepancies between model outputs and actual physical responses, and independently adjust control policies and hardware configurations. This creates a continuous development loop from algorithm development to real-world execution, feedback and refinement.
To meet embodied AI development requirements for experimental stability and reproducibility, RP1 incorporates systematic improvements across its mechanical structure, core actuators and manufacturing processes. RoboParty's in-house-developed ROMOMO actuators, structural optimization and manufacturing quality management are designed to improve consistency in physical response, overall reliability and maintainability. These measures help minimize the influence of hardware variation on experimental results and provide a stable physical platform for repeated model training and validation over extended periods.
Building a Shared Foundation for Global Innovation
RoboParty launched the RPO open-source project in January 2026, releasing mechanical and electrical design resources, along with training and deployment materials. The project has garnered more than 2,600 GitHub stars, enabling developers to reproduce and extend the robot design using publicly available resources.
RP1 continues this open-source approach, bringing together ROMOMO joint actuator modules, research from RoboParty Lab and the ongoing development of PartyOS to expand the technology foundation for robotics research and embodied AI model development.
"We believe the future of embodied AI should not be defined by just a handful of closed systems," said Yi Huang, founder of RoboParty. "With RP1, we want to open up more than code. We want to give researchers the opportunity to truly understand, modify and continuously advance robotic capabilities. When more teams can innovate on a shared technical foundation, the entire industry can move further forward."
RoboParty's vision is to make the future of embodied AI open to everyone ready to explore it.
GitHub: https://github.com/Roboparty/RP1
Website: https://roboparty.com
Media Contact: marketing@roboparty.com
About RoboParty
Founded in Shanghai in 2025, RoboParty develops humanoid robot hardware, motion-control technologies, robotics software and open development tools. Its product and technology portfolio includes the RPO and RP1 humanoid platforms, in-house-developed ROMOMO joint actuator modules, the RP Hand dexterous hand and the evolving PartyOS embodied AI system. Through openly available engineering resources and development tools, the company supports robotics research, embodied AI development and collaboration across teams.
** This press release is distributed by PR Newswire through automated distribution system, for which the client assumes full responsibility. **
Born to Be Open: RoboParty Launches RP1, a Full-Stack Open-Source Humanoid
Born to Be Open: RoboParty Launches RP1, a Full-Stack Open-Source Humanoid
Born to Be Open: RoboParty Launches RP1, a Full-Stack Open-Source Humanoid