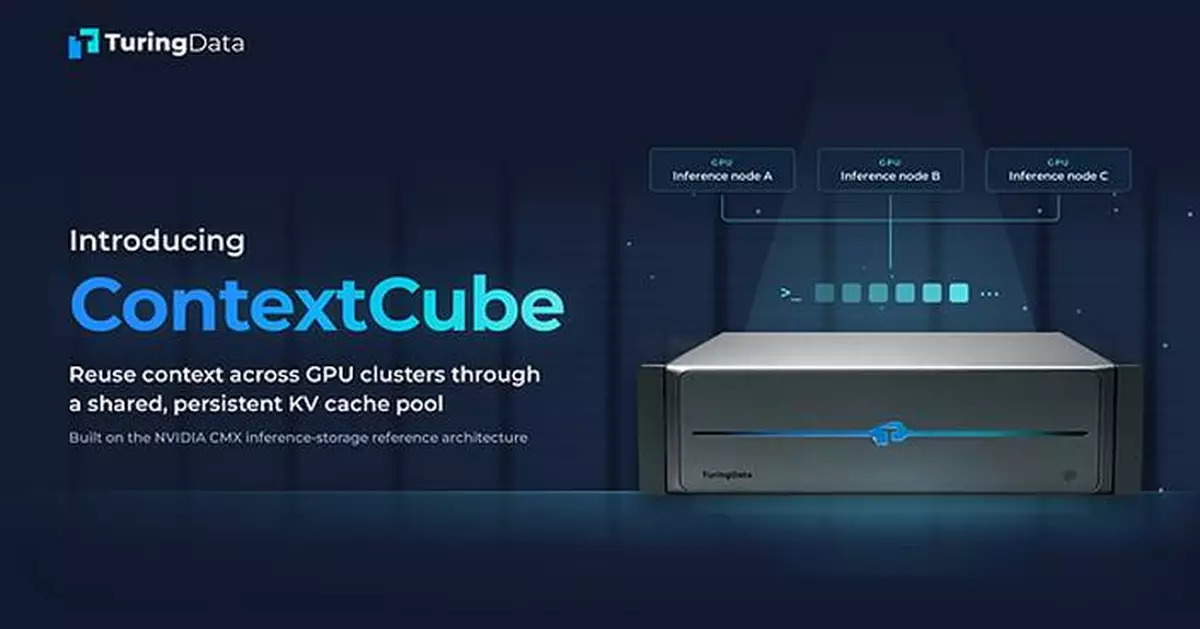
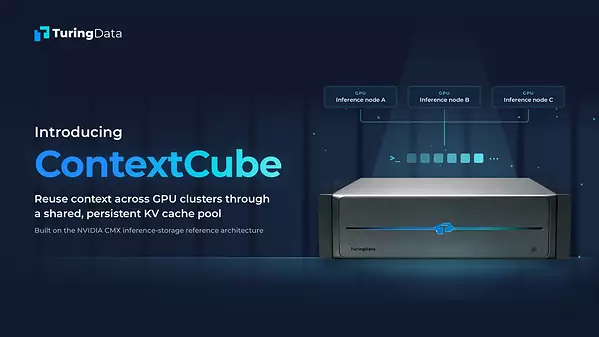
SINGAPORE, Sept. 29, 2026 /PRNewswire/ -- TuringData today launched ContextCube, a purpose-built KV cache appliance that gives AI inference clusters a shared, persistent pool of context.
Unveiled at Tech Week Singapore 2026, ContextCube enables participating inference nodes to retrieve matching cached KV over RDMA instead of repeatedly computing or storing the same context. This reduces time to first token, frees GPU cycles for token generation and supports greater throughput and concurrency.
As prompts grow longer and requests move between servers, valuable KV cache is often evicted or becomes inaccessible because it is held locally. ContextCube addresses this challenge by making previously computed context reusable across the cluster.
Designed on the NVIDIA CMX inference-storage reference architecture, ContextCube adds a shared Layer 3.5 alongside GPU HBM, DRAM and local NVMe storage. Active computation remains on GPUs while reusable context is retained in a large, cluster-wide cache.
Key capabilities include:
- Hundreds of terabytes of shared KV cache, with retention ranging from hours to weeks depending on configuration, workload and cache policy
- 120 GB/s KV bandwidth per appliance*
- DPU-based data movement using four NVIDIA BlueField-3 DPUs
- 26 U.2 NVMe drives and two 200 Gb/s ports per DPU
- Compatibility with inference engines including vLLM and SGLang, and KV cache software including TuringData Cache Fabric, LMCache and Mooncake
- Starting deployments from one appliance
ContextCube is designed for context-intensive workloads, including AI agents, coding assistants, multi-turn conversations, long-document processing, retrieval-augmented generation and large-scale "token factories."
"As context windows grow and AI agents move into production, the same context is being computed again and again on every server," said Jenvik Li, Founder and CEO of TuringData. "ContextCube gives the whole cluster one place to keep that work, so GPUs can spend their time generating new tokens instead of rebuilding old ones."
ContextCube is available to order now. Visit www.turingdata.io/contact-us.
About TuringData
Headquartered in Singapore, TuringData builds the data layer for AI infrastructure, helping enterprises and AI cloud providers improve GPU utilisation and token economics across training and inference. Learn more at www.turingdata.io.
*Actual performance depends on configuration and workload. NVIDIA and BlueField are trademarks and/or registered trademarks of NVIDIA Corporation in the United States and other countries.
** This press release is distributed by PR Newswire through automated distribution system, for which the client assumes full responsibility. **
TuringData Launches ContextCube at Tech Week Singapore 2026, Bringing Shared KV Cache to GPU Inference Clusters
PITTSBURGH, Sept. 29, 2026 /PRNewswire/ -- Sharpa, an AI robotics company focused on dexterous manipulation, today unveiled three flagship products at the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026: D01, an integrated robot built for dexterous manipulation; W02, a compact, lightweight dexterous hand with full-hand tactile sensing; and AE01, a haptic exoskeleton data glove for teleoperation and data capture.
The new lineup addresses three connected needs in robotics development: executing coordinated physical tasks, sensing and controlling contact with objects, and collecting human demonstrations to support robot learning. Together, the products expand Sharpa's hardware portfolio for developing robots that can use everyday tools and work in environments designed for people.
D01: the First Integrated Tactile-sensing Robot Built for Dexterous Manipulation
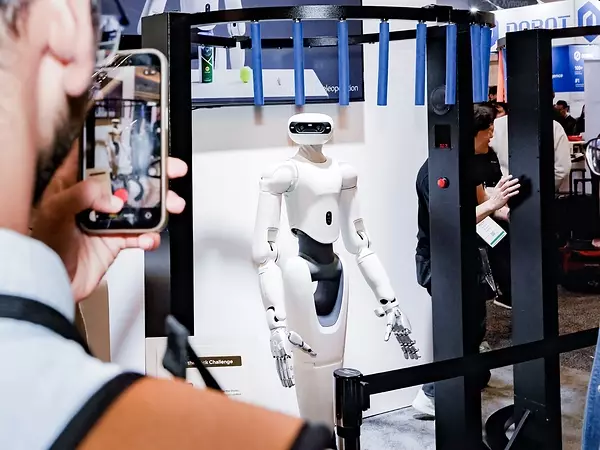
D01 brings together Sharpa Wave dexterous hands, seven-degree-of-freedom arms and whole-body electronic skin.
Built to combine strength, speed and precision, D01 offers an approximately 1:1 arm payload-to-weight ratio, a maximum end-effector speed exceeding 10.5 meters per second, a communication frequency of 1,000 Hz and end-effector repeatability of 0.2 millimeters. Human-scale spherical wrist joints support manipulation in workspaces and around tools designed for people.
D01's electronic skin extends contact sensing across the body, with a tactile sampling rate of 100 Hz and force resolution of 0.2 newtons. This additional feedback enables the robot to detect physical contact across its body and supports responsive interaction with objects and its surroundings.
W02: a Next-generation, Fully tactile, Ultra-compact and Lightweight Dexterous Hand
Building on Sharpa's W01 dexterous hand, W02 combines 21 active degrees of freedom with a compact structure weighing less than 750 grams. Its smaller, lighter design reduces loading on the robot arm and supports integration into workspaces built around human-hand dimensions.
W02 combines Sharpa's proprietary Dynamic Tactile Array at the fingertips with electronic skin across the fingers and palm. Fingertip sensors provide a force sensing range of 5 millinewtons to 30 newtons and spatial resolution of 1 millimeter. The electronic skin extends tactile coverage with a force sensing range of 0.1–20 newtons and spatial resolution of 5 millimeters.
The hand's zero-gap grasping capability supports the handling of slender objects such as chopsticks and fine cords. IP54-rated protection against dust and water splashes supports use in varied working environments. These features are designed to help robots handle everyday objects and tools while maintaining tactile feedback throughout the interaction.
AE01: a High-fidelity Haptic Exoskeleton Data Glove
AE01 is a high-fidelity haptic exoskeleton data glove designed for robot teleoperation and egocentric data capture. Its 22-degree-of-freedom design incorporates 22 encoders to capture joint motion, providing movement data for real-time robot control and the collection of manipulation demonstrations.
AE01 provides 256 levels of dynamic vibrotactile feedback at each fingertip, giving operators tactile cues to support adjustments during teleoperation. It also offers fingertip position repeatability of less than 1 millimeter.
The glove requires no additional user calibration and is designed to resist environmental interference, simplifying setup and supporting data collection across different operating environments. By combining motion capture with haptic feedback, AE01 gives researchers and developers a practical interface for guiding robotic actions and collecting training data.
Advancing Dexterous Manipulation to Real-World Tasks
With D01, W02 and AE01, Sharpa is expanding the tools available to develop, control and train robots for tasks involving sustained physical contact. The portfolio supports the company's broader goal of making robotic manipulation useful across increasingly complex workflows, from handling individual objects to completing connected tasks in real-world environments.
Visitors can explore Sharpa's latest products at Booth 514, David L. Lawrence Convention Center, Pittsburgh, Pennsylvania, through Sept. 30, 2026.
For more information, visit www.sharpa.com.
About Sharpa
Sharpa is an AI robotics company focused on dexterous manipulation, building robotic intelligence and full-stack systems designed for real-world deployment. By developing the foundational capabilities needed for general-purpose robots, Sharpa is working to bring them into practical applications. Sharpa believes robots should assist, not replace, humans—freeing people from repetitive and strenuous work so they can pursue more meaningful and inspiring endeavors. Now, Sharpa's products serve robotics companies, research institutions, and real-world applications such as food service. In the future, Sharpa's general-purpose robots will expand into a broader range of applications and, ultimately, into the home—giving people back time.
** This press release is distributed by PR Newswire through automated distribution system, for which the client assumes full responsibility. **
Sharpa Unveils Three Flagship Products: D01 Robot, W02 Dexterous Hand and AE01 Data Glove at IROS 2026